Optics Bench System Diagram: How to Draw a Ray Diagram 2026
To construct an optics layout, place the principal axis horizontally with the optical center at the lens midpoint. Mark focal points at exact equal focal lengths. Draw Ray 1 parallel to the axis refracting through the far focal point, and Ray 2 directly through the center without bending to map image structure.
📌 Key Takeaways
- Primary lens plane must be placed perpendicular to the principal axis zero line
- Focal distances (f) must be measured identically on both object and image sides
- Ray 1 runs parallel to axis and refracts directly through the focal point (F)
- Diverging rays require backward extensions using dashed lines to locate virtual images
- Measurement tolerance errors over 1mm invalidate calculated image magnification
Automotive optical engineering relies heavily on geometric ray tracing to map light propagation across Advanced Driver Assistance Systems (ADAS), Heads-Up Displays (HUD), matrix LED illumination modules, and LiDAR sensors. Learning how to draw a ray diagram provides mechanics, optical service technicians, and diagnostic engineers with a precise blueprint for pinpointing focal shifts, internal reflection losses, and geometric distortion. By establishing exact optical centers, principal focal points, and incident vector angles, you can accurately evaluate light behavior through single-lens and compound optic configurations. This guide details the standardized technical procedure for drafting precise ray diagrams on the bench to verify optical system layout and system alignment.


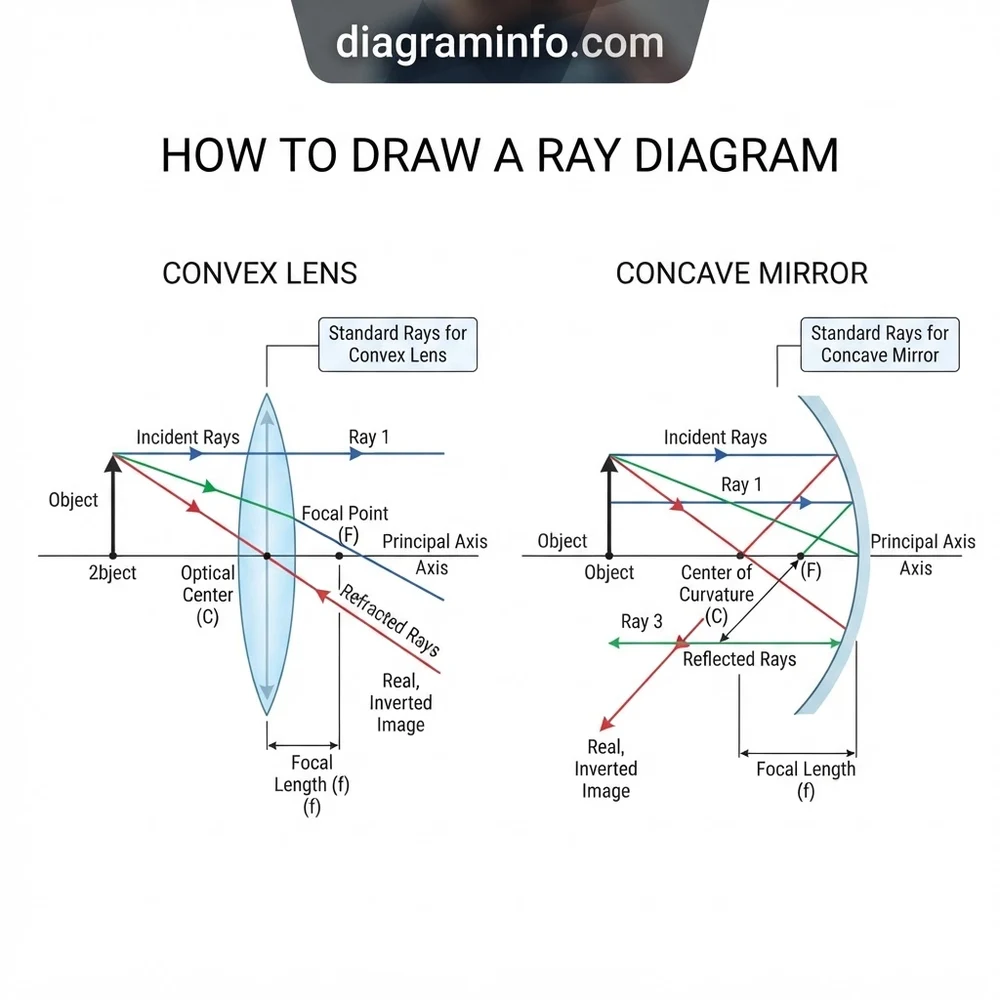
Ray Diagram Component Blueprint and Optical System Layout


Before constructing an engineering-grade schematic, you must establish the underlying geometric structure and component positions of the optical assembly. Modern automotive optics—ranging from adaptive front-lighting systems (AFS) to camera-based lane departure modules—depend on thin-lens and thick-lens approximations to predict ray convergence. Understanding every schematic component ensures that your manual or CAD-drawn ray trace reflects real-world optical behavior under OEM test conditions.
When plotting rays through automotive lenses, reference standard material refractive index ($n$) values at $20^\circ\text{C}$: Optical Crown Glass (BK7) $n = 1.5168$, Automotive Polycarbonate (PC) $n = 1.5860$, Acrylic (PMMA) $n = 1.4910$, Silicon $n = 3.44$ (LiDAR infrared range at $1550\text{ nm}$). Thermal operating range for calculations is $-40^\circ\text{C}$ to $+105^\circ\text{C}$.
Every standard ray blueprint relies on a fixed set of geometric reference marks and optical boundary lines. The table below outlines the essential structural elements required to complete a technical optical layout.
| Component Reference | Schematic Abbreviation | Technical Function & Mapping Role |
|---|---|---|
| Principal Axis | PA | Horizontal datum line drawn through the optical center perpendicular to lens vertical plane. |
| Optical Center | $O$ or $C$ | Geometric center point of the lens where passing rays experience zero angular deviation. |
| Primary Focal Point | $F_1$ | Point on PA where parallel incoming rays converge (or appear to diverge) after refraction. |
| Secondary Focal Point | $F_2$ | Symmetric point opposite $F_1$ positioned at exactly one focal length ($f$) from $O$. |
| Object Vector | $y$ or $O_v$ | Vertical arrow representing light source position, height, and distance ($u$) from $O$. |
| Image Vector | $y’$ or $I_v$ | Resultant real or virtual image position, height, and distance ($v$) from $O$. |
Principal Axis Baseline and Center Planes
The principal axis serves as your primary reference line. In bench diagnostics, all vertical displacement calculations for light emitters, LED arrays, and sensor grids stem directly from this datum line. The optical center ($O$) acts as the coordinate origin $(0,0)$. For thin lenses, refraction is mapped along a single vertical line drawn through $O$, simplifying multi-element calculations during initial HUD projector optical schematic design.
Focal Length Identification ($F_1$ and $F_2$)

Focal length ($f$) defines the converging power of an optical element. Manufacturer specifications provide $f$ in millimeters ($+f$ for convex/converging optics and $-f$ for concave/diverging optics). Mark $F_1$ and $F_2$ along the principal axis at equal measured distances from $O$. For complete diagnostic depth, also mark $2F_1$ and $2F_2$ points, which designate the $1:1$ magnification boundary plane.
How to Draw a Ray Diagram for Automotive Optical Alignment



To produce an accurate diagram for diagnosing sensor offset or beam deviation, follow this structured, step-by-step technical methodology. Using standardized scaling and geometric drawing tools eliminates drafting errors and ensures precise calculation of image location, orientation, and lateral magnification.


Select a uniform $1:1$ or $1:10$ spatial scale on engineering graph paper ($1\text{ grid unit} = 10\text{ mm}$). Maintain strict $1:1$ aspect ratios between the horizontal principal axis and vertical height axes. Deviations in vertical-to-horizontal scaling will cause geometric magnification calculation errors exceeding OEM tolerances ($\pm 0.5^\circ$).
Required Equipment & Diagnostics Bench Specs:
- Tools Needed: $1\text{ mm}$ grid millimeter graph paper (or CAD software like AutoCAD/DraftSight), fine-tip $0.3\text{ mm}$ mechanical pencil/pen, optical drafting protractor, steel scale ruler calibrated in $0.5\text{ mm}$ increments, scientific calculator.
- Safety Precautions: Wear Class 3R/3B laser protective safety eyewear when verifying ray paths against active laser diode test benches. Maintain a clean workspace free of oil and airborne dust contaminants.
- Estimated Time: 35 to 45 minutes for a complete multi-ray system blueprint.
Step 1: Establishing Baseline Axes and Optical Center Coordinates
Draw a horizontal line across the center of your drafting space to establish the principal axis. Draw a vertical line perpendicular to the principal axis at the center point to represent the lens principal plane ($O$). Label the intersection point as $O$. Measure out from $O$ along the horizontal axis using your calibrated scale and mark $F_1$, $2F_1$ on the left (object side), and $F_2$, $2F_2$ on the right (image side). For example, if $f = 40\text{ mm}$, place $F_1$ at $-40\text{ mm}$, $2F_1$ at $-80\text{ mm}$, $F_2$ at $+40\text{ mm}$, and $2F_2$ at $+80\text{ mm}$.
Step 2: Plotting the Primary Incident Parallel Vector (Ray 1)

Draw a vertical arrow on the left side of the lens at object distance $u$ to represent your light source or target object. Label the height of this arrow as $y$. From the tip of the object arrow, draw a horizontal ray straight toward the vertical principal plane of the lens, parallel to the principal axis. Mark this ray with an arrow head indicating direction toward the lens. Upon striking the vertical lens line at $O$, refract Ray 1 down directly through the secondary focal point $F_2$ on the right side of the lens, extending it into the image field.
Step 3: Drawing Central Axis Vector (Ray 2) and Focal Vector (Ray 3)
Construct Ray 2 by drawing a continuous straight line directly from the tip of the object arrow through the exact optical center point $O$. Under thin-lens paraxial rules, Ray 2 passes through $O$ without changing direction or suffering angular deviation. Next, construct Ray 3: draw a line from the tip of the object arrow passing through the primary focal point $F_1$ on the left until it strikes the vertical lens plane. From that lens interface point, refract Ray 3 horizontally parallel to the principal axis into the image region.


Step 4: Mapping Image Convergence and Magnification Ratio


Locate the point on the right side of the lens where Ray 1, Ray 2, and Ray 3 intersect. Draw a vertical arrow extending from the principal axis down (or up) to this intersection point. This arrow represents the resulting image vector ($y’$). Measure image distance $v$ from $O$ to the image baseline and image height $y’$. Verify your manual draft against the Gaussian Thin Lens Formula:
$$\frac{1}{f} = \frac{1}{u} + \frac{1}{v}$$
Calculate lateral magnification ($M$) using the measured heights and distances:
$$M = \frac{y’}{y} = -\frac{v}{u}$$
If $M$ is negative, the image is inverted and real (projectable onto a physical CMOS sensor or beam pattern target). If rays diverge on the right side, extend dashed line projections backward to the left to establish a virtual, upright image location—a necessary process during HUD projector optical schematic mapping.
Resolving Errors When Learning How to Draw Ray Diagrams for Optical Diagnostics



Ray tracing errors on the bench can lead to incorrect physical lens positioning, inaccurate sensor alignment, and failed recalibration routines on ADAS cameras or matrix headlights. Recognizing geometric distortions and drafting mistakes allows you to quickly correct blueprints before making mechanical adjustments to optic mounts.
Incorrect optical path mapping during high-power Matrix LED or LiDAR diode alignment can concentrate light energy onto internal polymer optic housings. Always verify focal point calculations ($f$) on paper before applying full operational current to bench emitters.
Correcting Spherical Aberration and Paraxial Ray Skew
Standard ray diagrams rely on paraxial approximations, assuming all incident light vectors strike near the lens center at small angles ($\sin\theta \approx \theta$). In wide-aperture automotive projection optics (such as thick LED lenses), peripheral rays refract more intensely than central rays, causing spherical aberration. When drafting wide-aperture systems, do not rely on a single vertical line plane; draw the actual physical lens radius surface and apply Snell’s Law ($n_1 \sin\theta_1 = n_2 \sin\theta_2$) at both entry and exit surfaces to resolve marginal ray skew.
Resolving Index Misalignments in Multi-Lens Automotive Assemblies
When modeling compound optic stacks—such as a multi-element automotive camera lens—single-lens rules are insufficient. An error occurs if you attempt to trace rays through a second lens without establishing the image of the first lens as the object for the second lens. To resolve this, map Lens A first, find its virtual or real image point, and use that image coordinate as the object baseline for Lens B. For comprehensive procedures on bench-testing physical alignment targets, consult our guide on headlight beam alignment procedures and LiDAR optical sensor calibration.
Frequently Asked How to Draw a Ray Diagram Questions
How Does Lens Thickness Affect Geometric Ray Tracing Specs?
Thin-lens schematics assume lens thickness ($t$) is negligible compared to focal length ($f$), allowing all refraction to be modeled along a single central vertical axis. In automotive optics where lens thickness is significant (such as thick polymer LED projector lenses where $t > 0.1f$), you must draw two principal planes: the primary principal plane ($H_1$) and secondary principal plane ($H_2$). Refraction vectors entering the lens shift parallel between $H_1$ and $H_2$, adding precise physical offsets to calculated image distances.


What Is the Difference Between Real and Virtual Image Rays in HUD Diagrams?
Real image rays physically intersect at a projection point in space and can be captured on a screen or camera sensor. In ray diagrams, real rays are drawn as solid lines. Virtual image rays do not physically cross; instead, human eyes or receiving optics perceive light as diverging from an imaginary point behind the mirror or lens assembly. In automotive Heads-Up Displays (HUDs), virtual image rays are drawn as dashed lines extended backward from reflecting mirrors, placing the projected display image 2 to 7 meters past the windshield out over the hood.
Why Are Paraxial Approximations Used in Automotive LiDAR Ray Schematics?
Paraxial approximations simplify complex trigonometric wave calculations by assuming ray angles relative to the principal axis remain below $10^\circ$. At these small angles, $\sin\theta \approx \tan\theta \approx \theta$ (in radians). This simplification allows technicians to quickly draw linear ray traces and calculate primary focal positions, beam divergence, and receiver array placement on the bench without performing heavy CAD ray-trace rendering for every diagnostic step.
How Do You Plot Refraction Across Aspheric LED Projector Elements?
Unlike spherical optics that maintain a uniform radius of curvature ($R$), aspheric projector lenses alter their surface curvature from the center axis outward to eliminate spherical aberrations. To manually draw a ray diagram for an aspheric element, divide the lens surface into discrete radial segments, measure the localized surface normal angle ($\theta_n$) at the exact point of incident ray impact, and apply Snell’s Law ($n_1 \sin\theta_1 = n_2 \sin\theta_2$) locally for each individual ray path.
What Ruler and Scale Standards Apply to Bench-Level Optical Blueprints?
Bench blueprints must adhere to ISO 128 / DIN standards for technical drawing symbols and ISO 10110 standards for optical element representation. Scale factors must maintain absolute linear symmetry ($1:1$, $1:2$, or $1:10$). All linear distances ($f$, $u$, $v$, $t$) must be noted in millimeters ($mm$), and angular vectors must be marked in decimal degrees ($\pm 0.1^\circ$) using certified drafting instruments or vector CAD software.
Step-by-Step Guide to Understanding the How To Draw A Ray Diagram
Identify – Establish the optical element type, primary object height, and exact focal length specifications for the system setup.
Locate – Position the horizontal principal axis line and place the central optical element interface cleanly at the origin.
Reference – Mark focal points F1 and F2 symmetrically along the principal axis using precise metric measurements on both sides.
Connect/Route – Project key rays parallel to the principal axis and directly through the optical center to locate their intersection.
Verify – Draw the final image arrow at the ray convergence point and calculate total magnification relative to object size.
Troubleshoot – Check focal point symmetry and extend dashed lines backwards if rays diverge to locate virtual image formation.