Golden Technologies Lift Chair Parts Diagram: 2026 Guide
The Golden Technologies lift chair parts diagram details the mechanical frame layout and electrical drive system. It maps the 29V DC linear actuator motor, 5-pin hand pendant control connection, transformer power supply with dual 9V battery backup, scissor lift frame assembly, and heavy-duty recline spring configuration for precise electrical routing and hardware replacement.
📌 Key Takeaways
- Identifies standard 29V DC linear actuator motor specs and 5-pin DIN hand control connector pinouts.
- Shows critical drive system structure, including scissor lift frame pivots and recline spring mounting points.
- Safety tip: Always disconnect the 110V AC main power supply before servicing control boxes or wiring harness.
- Most common failure point is the hand control cord fatigue near the strain relief socket or quick-disconnect junction.
- Replace plug-and-play hand pendants and transformers DIY; seek certified service for welded steel frame bent linkages.
Golden Technologies lift chairs integrate advanced electromechanical systems designed to provide smooth, reliable articulation for mobility assistance. Understanding the complete electrical, electronic, and mechanical configuration requires a detailed technical breakdown of the factory circuit schematics and structural layouts. Modern lift recliners—ranging from standard single-motor units to dual-motor AutoDrive series (such as the Comforter, Maxicomfort PR-535, and Daytripper series)—rely on precision linear actuators, switch-mode transformers, micro-switch hand controllers, and heavy-gauge steel scissor linkages. Service technicians and repair specialists must analyze these components systematically using official schematics to perform accurate diagnostics, pinout verification, component replacement, and mechanical realignments.


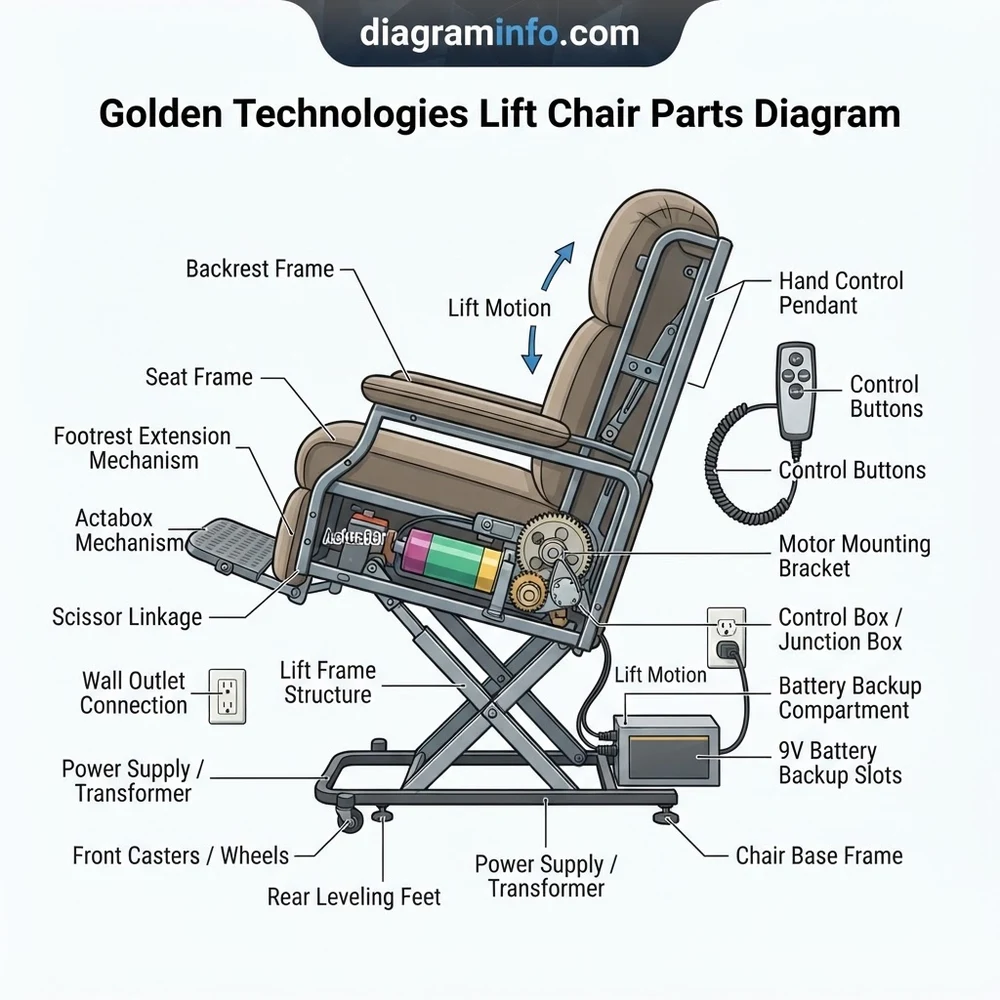
Golden Technologies Lift Chair Parts Diagram: Core Structural Breakdown


Analyzing a golden technologies lift chair parts diagram requires separating the chair into two primary domains: the high-torque mechanical lifting frame and the low-voltage direct current (DC) electrical circuit. According to OEM specifications, Golden Technologies utilizes low-voltage DC drive systems powered by external switch-mode power supplies (SMPS) to reduce shock hazards and maintain whisper-quiet motor operation under continuous loads ranging from 375 lbs to over 500 lbs.
Linear Actuator Drive Motor Specifications and Mount Configuration
The core motion engine in the system schematic is the linear actuator (commonly manufactured by Dewert Okin, Kaidi, or Limoss). The actuator translates rotational motor torque into smooth axial thrust along an internal acme screw drive or worm gear assembly. Most single-motor models employ a 24V DC to 29V DC permanent magnet motor running at an unloaded speed of approximately 5–7 mm/sec. The actuator housing mounts to the steel chassis via quick-release clevis pins secured with hairpins or bow-tie cotter clips. Axial forces are transferred directly from the motor push-rod head into the primary torque tube, which rotates the elevation arm assemblies.
Switch-Mode Transformer and Battery Backup Subsystem


The power supply enclosure converts 120V AC household voltage to a regulated 29V DC output at 2.0A to 2.5A continuous rating. The power brick contains an integrated thermal overload fuse rated at 115°C to 130°C and secondary auto-resetting PTC thermistors for current limiting. A dual 9-volt (18V DC total emergency output) battery harness is integrated into the housing circuit board via isolation diodes. This emergency backup power pathway supplies temporary direct current to the linear actuator drive motor in the event of an AC mains power failure, allowing a single full descent cycle.
Hand Pendant Control Harness Pinout and Architecture
The user interface consists of a multi-button hand pendant wired directly to the primary junction block or actuator motor casing. Golden Technologies utilizes two primary connector standards across their line: a legacy 5-pin DIN connector and a modern 8-pin DIN connector (used in AutoDrive and programmable memory recliners). The hand pendant houses momentary micro-switches or a printed circuit board (PCB) equipped with a microcontroller for complex dual-actuator coordination. Pin arrangements carry 29V DC power supply lines, ground return paths, and directional switch leg logic leads.
Steel Scissor Frame Assembly and Clevis Linkage Hardware


The lower structural blueprint comprises cold-rolled tubular steel frames, heavy-gauge sheet steel scissor arms, cross-support steel torque tubes, and nylon/polyurethane pivot bushings. Anti-friction synthetic bushings prevent metal-to-metal wear at pivot points. Structural stability relies on hardened steel clevis pins rated for shear loads exceeding 2,000 lbs. Understanding the spatial relationship between the recline-articulation arm and the lift-base frame is essential when performing frame squareness checks or replacing damaged scissor linkages.


| Component Part | OEM Specification / Model | Electrical / Mechanical Specs | Diagram Reference ID |
|---|---|---|---|
| Linear Actuator Motor | Okin Deltadrive / Betadrive / Kaidi KDPT007 | 24V–29V DC, 2.0A, 1.5–2.0 kN Push Thrust | ACT-101 |
| Power Transformer | Okin ZB-A290020-A / Golden Switch Mode | Input: 100-240V AC; Output: 29V DC @ 2.0A | PWR-201 |
| Hand Controller (Standard) | 2-Button Quick-Connect (5-Pin DIN) | 29V DC Signal Switch, Direct Motor Pass-Through | HND-301 |
| Hand Controller (AutoDrive) | 4-Button / 6-Button AutoDrive Memory (8-Pin) | Digital Microcontroller Interface, Low-Current Logic | HND-302 |
| Lift Base Scissor Frame | Golden Heavy-Duty Powder-Coated Chassis | 11-Gauge Tubular Steel, Synthetic Bushings | FRM-401 |
Analyzing the Golden Technologies Lift Chair Wiring System Layout


The electrical layout of a Golden Technologies lift chair functions as a closed-loop low-voltage DC system. Understanding how voltage moves from the wall outlet through the transformer, hand control, and actuator coil is vital for systematic circuit tracing. For technicians working on complex multi-motor recliners, cross-referencing this wiring architecture with a power lift chair motor replacement guide ensures correct pin polarity during component installation.
Single-Motor Series Circuit Architecture
In standard single-motor setups, 120V AC is stepped down and rectified inside the external switch-mode power supply to yield 29V DC. This DC potential is fed directly through a 2-conductor extension cable to the motor’s primary junction point or control housing. When an operator presses the UP or DOWN switch on a standard 5-pin hand control, the mechanical switch contacts route current directly through the actuator motor’s internal field windings. Reversing the switch direction inverts the DC voltage polarity delivered to the motor leads (+29V DC for extension/lift, -29V DC for retraction/recline).
Direct-drive 5-pin switch pendants swap positive and ground connections internally across the DC motor leads. Pin 1 (+29V DC) and Pin 2 (DC Ground) feed the switch contacts. When UP is engaged, Pin 3 receives +29V DC relative to Pin 4. When DOWN is engaged, internal cross-bar connections swap the leads, feeding +29V DC to Pin 4 relative to Pin 3.
Dual-Motor AutoDrive Configuration for Independent Back and Foot Control


In high-end Maxicomfort models (such as the PR-535 or PR-756 featuring AutoDrive positioning), the system schematic shifts from direct switch pass-through logic to an electronic control module (ECM) circuit. The 8-pin hand pendant communicates low-current digital switch inputs to a logic board mounted inside the dual-actuator primary housing or an external control box. The board processes these signals and activates solid-state or electromagnetic relays that independently route 29V DC power to the backrest linear motor and footrest linear motor.


• Pin 1: +29V DC Unregulated Power Supply Input
• Pin 2: Direct Current Common Ground Return
• Pin 3: Motor Terminal A (Actuator Extend / Lift Direction)
• Pin 4: Motor Terminal B (Actuator Retract / Recline Direction)
• Pin 5: Key Switch Pass-Through / Security Interlock Relay Line
How to Read a Golden Technologies Lift Chair Parts Diagram Schematic


To perform accurate service using a golden technologies lift chair parts diagram, a technician must systematically execute diagnosis steps using an automotive or electrical digital multimeter (DMM). Follow this three-step schematic tracing methodology to pinpoint circuit interruptions, high resistance faults, or mechanical structural binding.
Step 1: Mapping Low-Voltage DC Input and Relay Interlocks
Begin by verifying supply voltage at the transformer output jack before dissecting the chair frame or cutting cable ties. Plug the SMPS transformer into a verified 120V AC wall outlet. Set your digital multimeter to DC Volts (V=). Insert the DMM probes into the 2-pin barrel or female plug extending from the power transformer.
The reading must display between 27.5V DC and 30.5V DC unloaded. If voltage reads 0V DC, inspect the AC line cord continuity and check for blown secondary fuses inside the power brick. If supply voltage is verified, trace the main DC feed line to where it joins the motor wiring harness assembly.
Step 2: Conducting Resistance and Continuity Tests Across Harness Leads
Disconnect main power to prevent blowing internal DMM fuses during resistance testing. Disconnect the hand pendant from the 5-pin or 8-pin extension harness. Set the multimeter to Resistance (Ohms Ω) or Continuity Beep mode. Refer to the manufacturer wiring layout to isolate the switch contacts.
Insert DMM lead probes across Pin 1 and Pin 3 on the male hand pendant connector. Depress the “UP” switch button. The multimeter should display near-zero resistance (less than 0.5 Ohms). Next, test across Pin 1 and Pin 4 while depressing the “DOWN” switch button. A reading of Infinite Resistance (O.L.) during switch actuation indicates burnt internal micro-switch contacts or a broken copper flex conductor within the coiled pendant cord. Refer to detailed mobility equipment actuator pinout diagrams when cross-referencing non-standard wire colors.
Step 3: Bench Testing Linear Actuators with Direct DC Power
If hand control signals and power supply voltages pass spec, isolate the linear actuator motor to confirm internal motor health. Unclip the actuator clevis pins and remove the motor assembly from the steel lift chassis.


When bench testing a linear actuator separated from the lift chair frame, the drive shaft extension tube will rotate or extend rapidly upon applying power. Secure the actuator body in a bench vise using rubber jaw protectors. Keep fingers clear of the traveling clevis head and rotating lead screw drive mechanism to prevent severe crush injuries.
Apply an isolated 24V DC to 29V DC source (or two 12V automotive batteries connected in series) directly across the motor’s primary spade terminals or Pin 3 and Pin 4 of the motor input socket. The drive shaft stroke tube should extend smoothly without excessive acoustic whine or mechanical chatter. Reverse battery leads to verify full retraction stroke. A motor drawing over 4.0 Amps unloaded indicates shorted armature windings, a bent inner acme screw, or broken planetary gear teeth.
Troubleshooting Electrical and Mechanical Failures via the System Blueprint
When systemic breakdowns occur, mapping physical symptoms against the mechanical blueprint and electrical schematic speeds up diagnostic turnaround. Modern lift recliners experience specific failure modes tied directly to wear patterns on structural pivot joints, switch contacts, and motor stroke limits.
Symptom 1: Actuator Motor Hums but Mechanical Arm Does Not Travel
If the actuator motor runs or emits a distinct low-frequency hum when energized, but the chair does not rise or recline, the electrical control path is functioning correctly. The fault lies within the mechanical gear train or internal drive coupling shown on the motor component schematic.
This condition typically stems from a stripped nylon worm gear or a sheared drive nut along the internal acme lead screw. Disassemble the actuator gear housing cover. Inspect the main synthetic drive gear for stripped teeth or metal shavings. If gear teeth are destroyed, replace the linear actuator motor assembly. Additionally, inspect the scissor frame linkage to ensure a jammed pivot arm did not cause the structural overload that stripped the motor gear.
Symptom 2: Complete System Inoperation with Zero DC Voltage Output
When the lift chair is completely unresponsive and the hand pendant LED fails to illuminate, start at the AC power input side of the schematic. Test the wall outlet with a known working load. If AC voltage is present, check the output indicator LED on the Golden Technologies power transformer block.
An unlit transformer LED indicates an internal open circuit. Unplug the unit and check the DC output cable for physical damage, pinching, or severe wire fatigue caused by the scissor frame moving across the cable run. If external wiring is intact, internal primary thermal fuses have likely tripped due to excessive duty cycle continuous operation (e.g., exceeding the 2-minute ON / 18-minute OFF duty cycle rating). Allow the power supply to cool for 30 minutes to reset automatic thermal cutouts. If power is not restored, replace the transformer module.
Symptom 3: Intermittent Power Loss During Recline or Lift Cycles
Intermittent operation that cuts out only at specific points in the recline travel arc typically points to a mechanical wire harness strain issue rather than an electronic component failure. As the scissor frame articulates, the main wiring harness flexes along the lower structural frame rails.
Inspect the wire retention clips along the lower steel torque tubes on the frame diagram. Look for crushed wire insulation, broken strain reliefs, or loose molex/DIN locking rings at the motor housing junction. Re-route damaged wire harnesses clear of all steel scissor pinch points, leaving adequate slack loops at primary pivot axes. Fasten cables using UV-resistant nylon cable ties and protective spiral wire loom wrap.
Symptom 4: Structural Scissor Frame Binding or Uneven Lift Angle
If the chair lifts unevenly or produces a metallic popping noise during articulation, consult the lower frame structural layout. Measure cross-corner diagonal distances along the steel base weldments using a tape measure to check frame squareness.
Inspect nylon pivot flange bushings located at each scissor arm junction bolt. Worn, cracked, or missing flange bushings cause steel-on-steel friction, leading to binding and asymmetrical lifting. Torque all frame pivot shoulder bolts to 12–15 Nm (8.8–11 ft-lbs). Replace deformed clevis pins or distorted scissor arm channels to re-establish factory geometry, referencing heavy-duty recliner frame alignment specs for exact mechanical clearances.
Golden Technologies Lift Chair Parts Diagram Technical Reference FAQ
What is the standard pinout for a 5-pin DIN Golden Technologies hand pendant?
Standard 5-pin DIN hand controls used on Golden Technologies lift chairs feature a 180-degree circular pin layout. Pin 1 carries +29V DC power from the transformer, Pin 2 serves as DC Ground, Pin 3 connects to Motor Terminal A (UP circuit), Pin 4 connects to Motor Terminal B (DOWN circuit), and Pin 5 serves as a switch logic return or safety interlock lead. Pin assignments may vary slightly on legacy Okin Megamat systems, so always test continuity prior to wire splicing.
How do I bypass the switch-mode power transformer to test the linear actuator directly?
To test a 24V–29V DC linear actuator motor without using the standard OEM power supply unit, connect two 12-volt sealed lead-acid (SLA) batteries in series to
What causes frame binding and how is it identified on the mechanical blueprint?
Frame binding occurs when the parallel alignment of the steel scissor arms shifts out of square, causing extreme lateral friction on pivot bolts and clevis pins. On the mechanical layout, this is identified by measuring equal diagonal distances across the base rectangle frame. If diagonals differ by more than 1/4 inch (6.35 mm), the frame is wracked. Binding is usually caused by operating the chair on an uneven floor surface, worn nylon pivot bushings, bent torque tube arms, or unbalanced weight distribution on the footrest.
Are Dewert Okin actuators interchangeable across different Golden Technologies models?
Dewert Okin actuators are interchangeable only if physical stroke length, retracted mounting length (clevis-to-clevis dimension), thrust rating (Newtons), and electrical connector types match perfectly. For example, an Okin Deltadrive actuator with a 160mm stroke cannot replace an Okin Betadrive with a 200mm stroke without causing severe structural frame binding or over-extension damage. Always match the exact motor part number found on the linear actuator data tag.
How does the 9V battery backup circuit integrate into the main power schematic?
The dual 9V battery backup system connects to the secondary DC side of the power supply board through isolation Schottky diodes. Under normal conditions, line power holds the diode in a reverse-biased state, preventing battery drain. When 120V AC power cuts out, the diode becomes forward-biased, allowing the two 9V batteries (producing 18V DC) to supply current to the hand switch and motor circuit. Because output voltage is lower than the standard 29V DC, the motor operates at a slower speed during battery-powered lower cycles.
Step-by-Step Guide to Understanding the Golden Technologies Lift Chair Parts Diagram
Identify – Examine the Golden Technologies model tag on the lower rear frame to match diagram specs.
Locate – Find the 29V DC motor assembly, transformer box, and hand control port layout on the structure.
Reference – Cross-check wire color codes and 5-pin DIN connector pinouts against the schematic layout.
Connect/Route – Route control cables clear of moving scissor mechanisms and secure with retention zip-ties.
Verify – Perform a full recline and lift cycle test under low-voltage power to ensure smooth drive travel.
Troubleshoot – Test thermal inline fuses and transformer output voltage if motorized lift motion fails.